Nolan · Robotics through experimentation
Explore the motion.
Understand the robot.
Nolan is a six-servo bipedal robot simulation and learning platform by SkillUp Circle. Connect joint movements, Arduino code, and physics to investigate how a robot moves—and why it loses balance.
Inside Nolan
A practical workspace for robotics learning
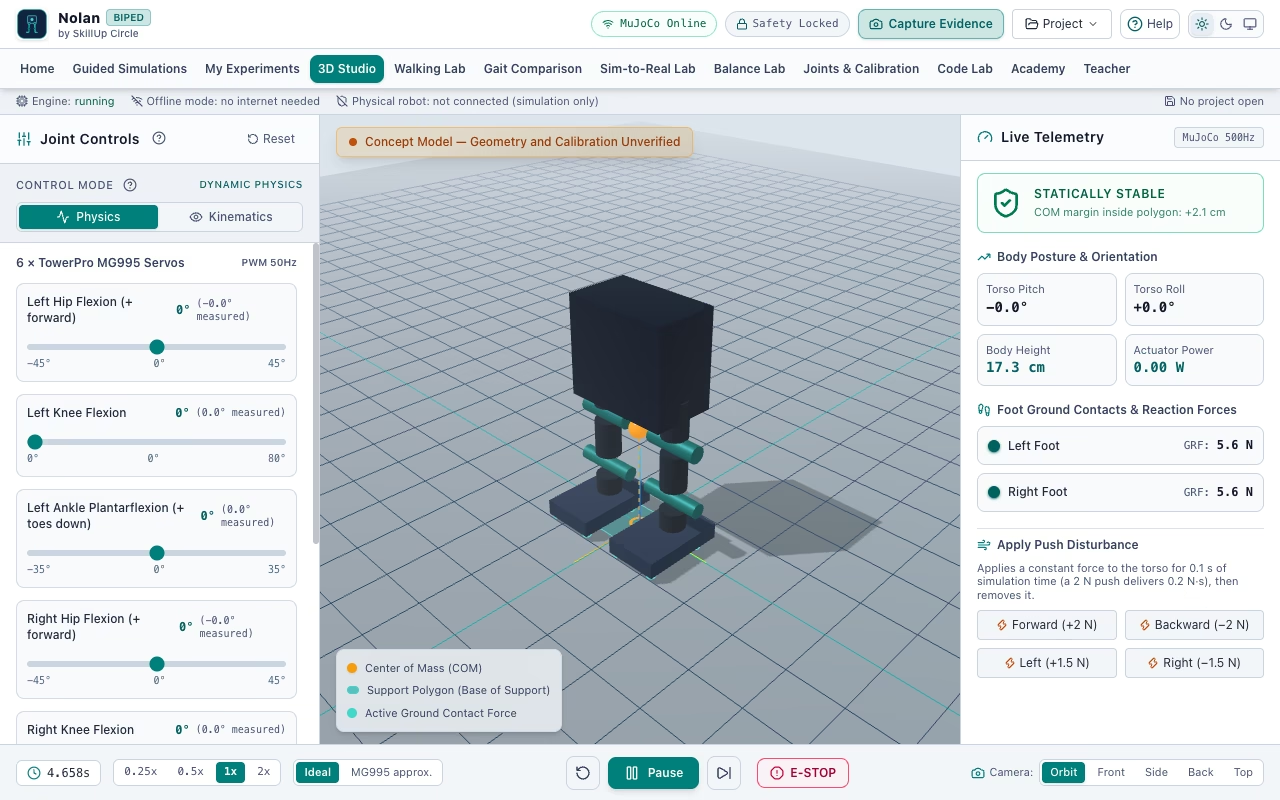
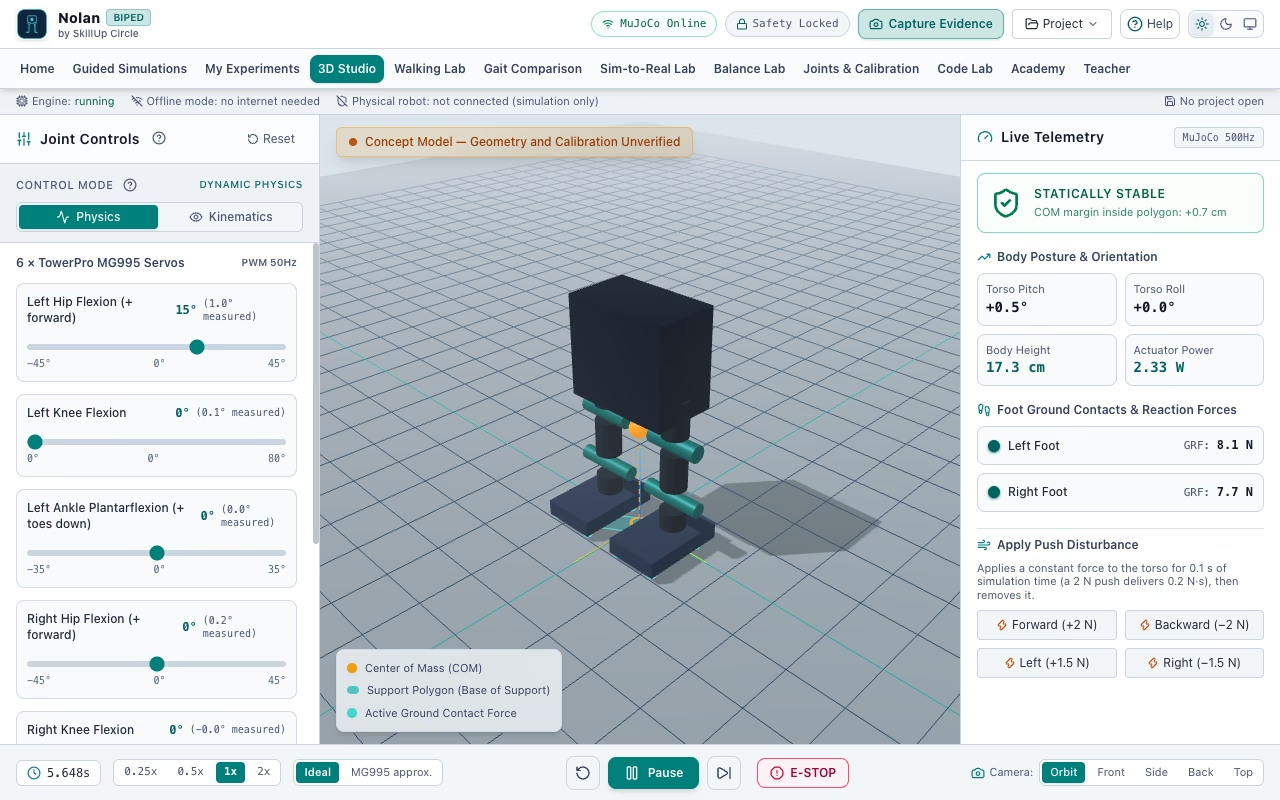
3D Physics Studio
Explore the simulated robot in a Three.js viewport powered by MuJoCo. Inspect centre of mass, the support polygon, and ground reaction forces.
Joint & Servo Controls
Adjust six joint targets, inspect simulated joint angles, and explore the effect of mechanical movement limits.
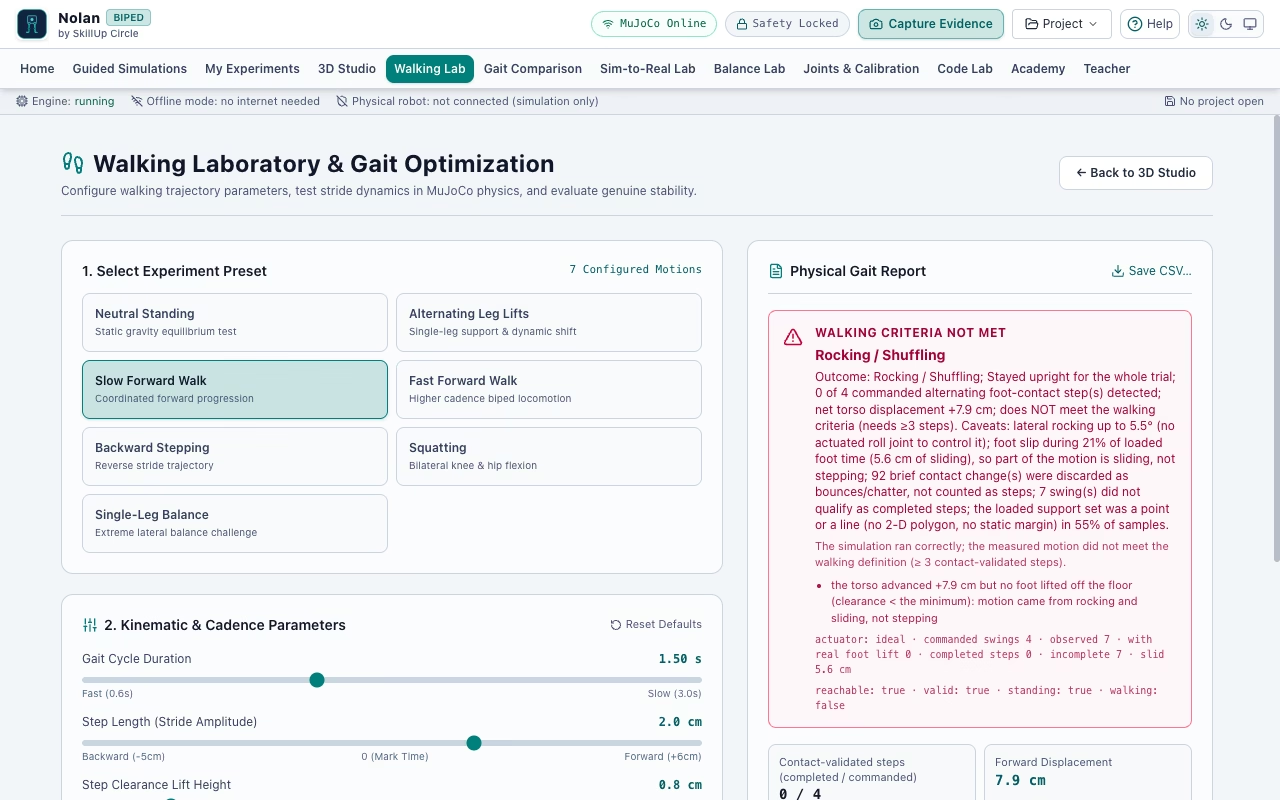
Walking Laboratory
Change gait parameters and evaluate contact, movement, slipping, and balance. Use unsuccessful trials as evidence for the next experiment.
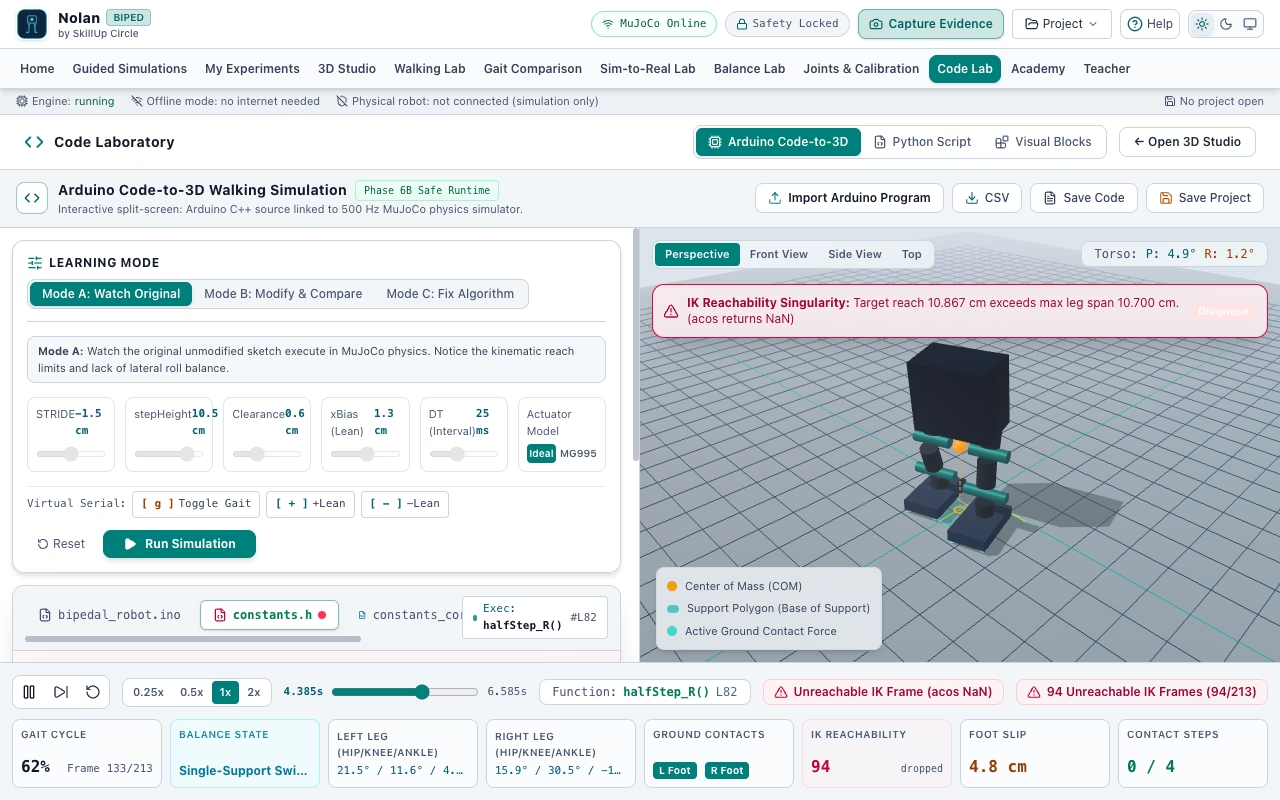
Arduino Code-to-3D
Parse supported Arduino firmware for kinematic playback, timeline inspection, and inverse-kinematics reachability checks. This is not a general-purpose Arduino compiler.
Balance & Virtual IMU
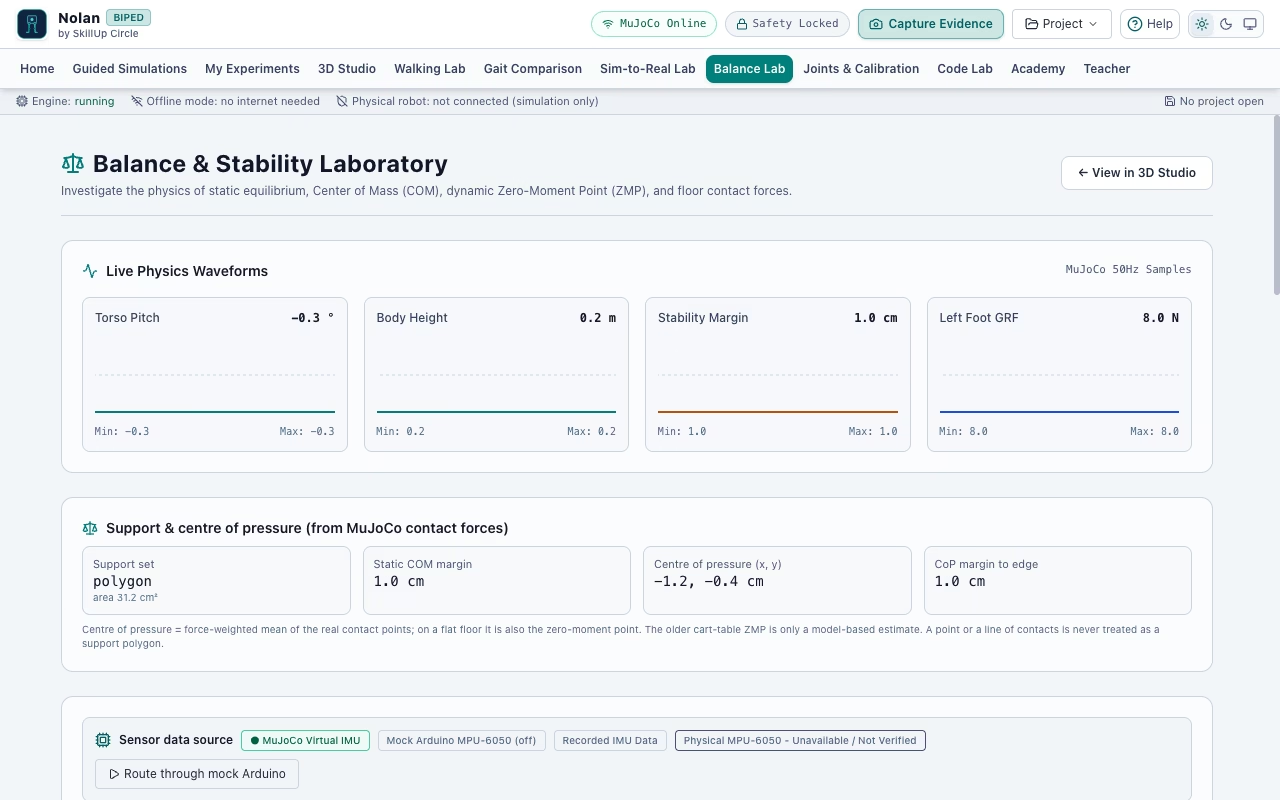
Investigate simulated accelerometer and gyroscope signals and compare orientation estimates with the physics simulation.
Experiment Notebook
Record observations, capture simulation evidence, reflect on outcomes, and export experiment reports.
Learn by investigating
A motion sequence starts the experiment.
Nolan helps learners ask questions about a motion and inspect the results, rather than assume a sequence will work.
Stable forward walking remains an experimental challenge in the current model.
Ground contact
Does the foot actually leave the ground?
Slipping
Does a change in stride improve movement or increase slipping?
Geometry
Can the leg reach the target within its joint limits?
Balance
Can the robot support its weight over its support polygon?
Who is Nolan for?
- Engineering students in robotics, electronics, mechanical engineering, IoT, and related branches.
- First-year students learning how code, actuators, and mechanics connect.
- Faculty planning practical robotics sessions.
- Makers, competition teams, and researchers exploring biped motion.
Built around a six-servo biped
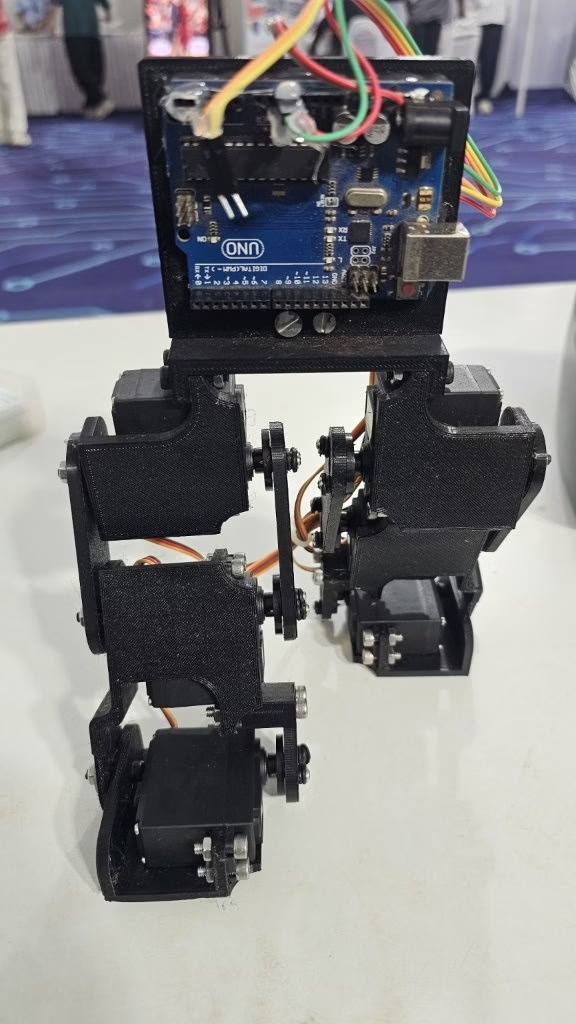
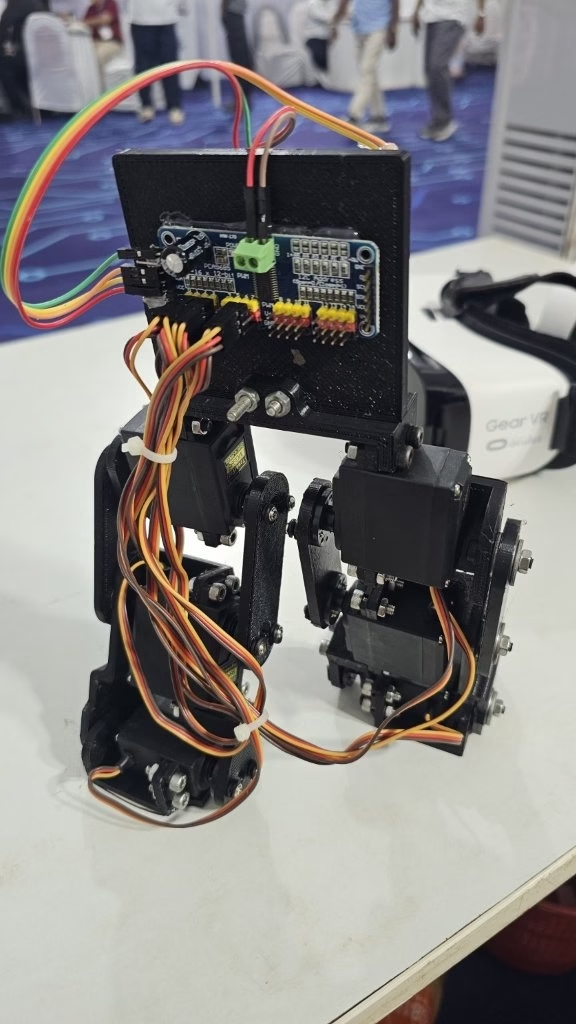
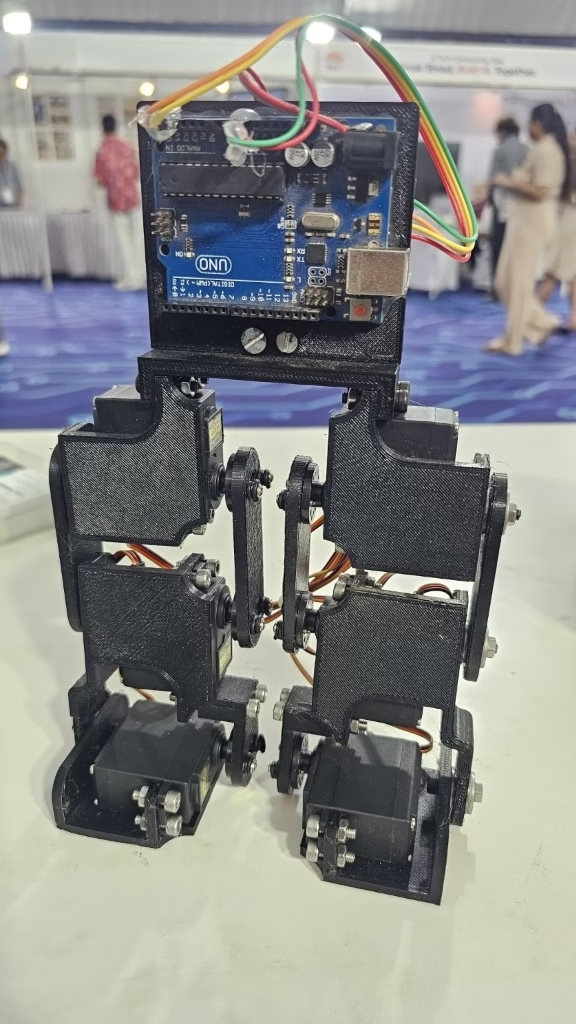
The reference hardware uses an Arduino UNO, a PCA9685 servo controller, and six MG995 servos. The application supports exploring movement in simulation before physical experiments.
Virtual IMU work uses an MPU-6050-style accelerometer and gyroscope model. Physical IMU streaming and live servo operation are separate integration milestones.
Current project status
Status based on the supplied project preparation report; consult the repository for subsequent changes.
Area
Current scope
Simulation & learning labs
Physics studio, joint controls, gait experiments, virtual IMU, and notebook workflows reported as implemented.
Sim-to-real preview
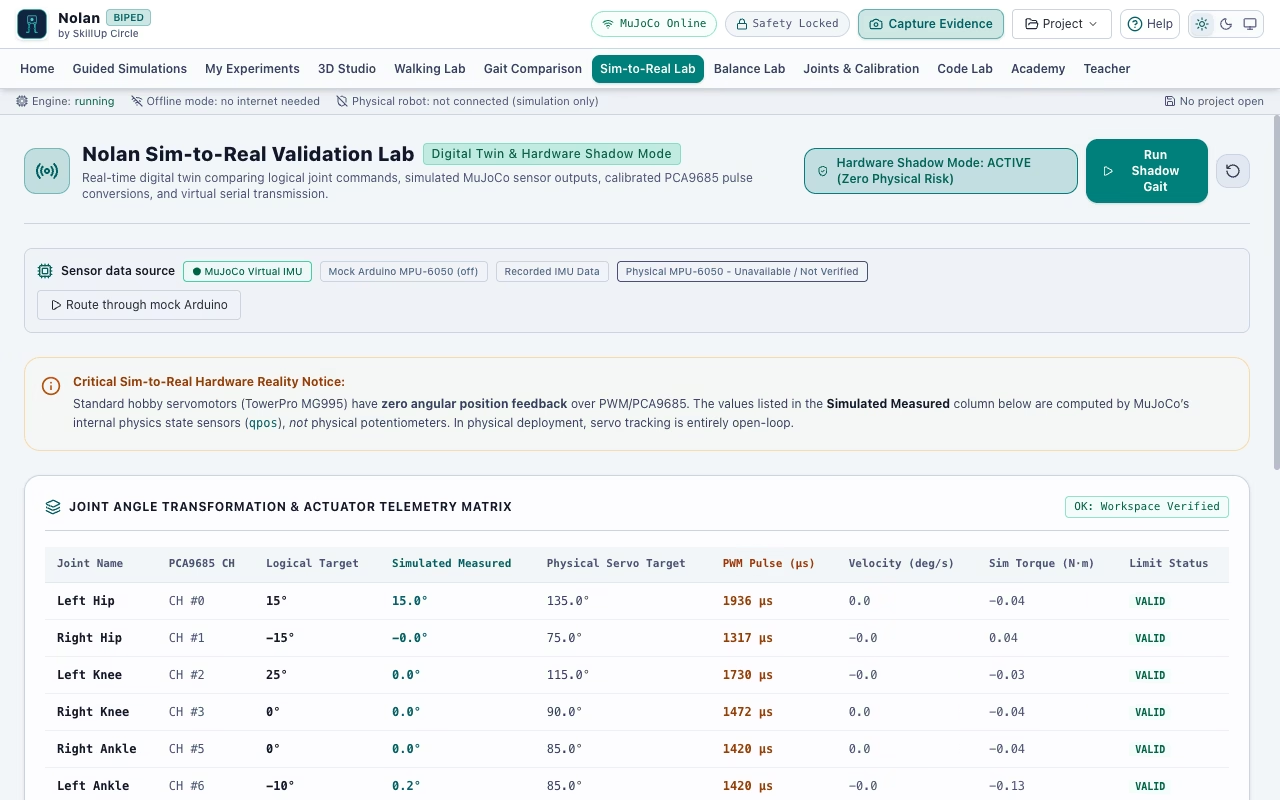
Experimental software shadow mode. Displayed joint states and telemetry are simulated.
Physical hardware
Live servo actuation is locked in dry-run mode. Physical IMU streaming is planned.
Desktop platforms
macOS Apple Silicon validated; Windows and Linux hardware certification pending.
Frequently asked questions
What is Nolan?
Nolan is SkillUp Circle’s six-servo bipedal robot simulation and learning application, designed for exploring motion, code, balance, and experiments.
Does Nolan make the physical robot walk?
The current release focuses on simulation and dry-run workflows. Stable physical walking has not been established by the supplied release report.
Are the displayed servo angles measured from hardware?
The reported joint states come from the physics simulation. Standard MG995 PWM control does not provide physical angle feedback to this application.
Where can I get the code and setup instructions?
Visit the public GitHub repository for source code, setup instructions, current platform status, and contribution guidance. Check the repository license and individual asset terms before reuse.
Bring robotics experiments to your classroom.
Explore Nolan, build on the project, or discuss a SkillUp Circle robotics workshop for your institution.